Introduction
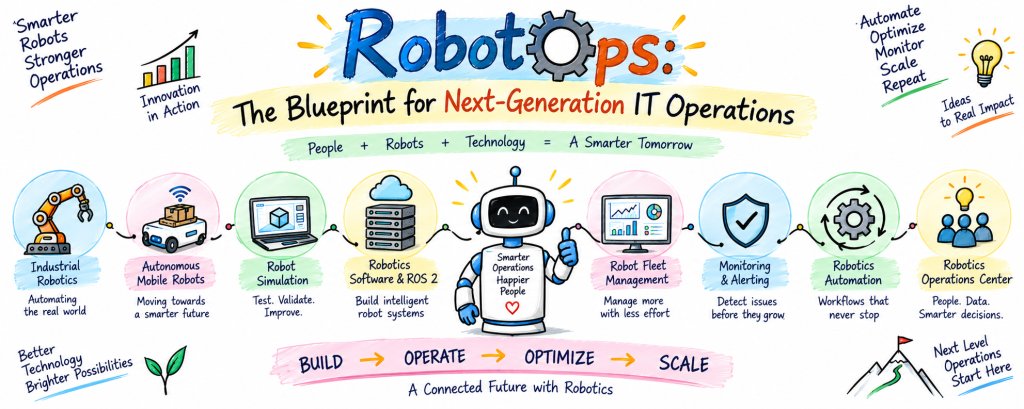
Robots now handle many jobs that once needed constant human effort. They move goods, inspect products, carry supplies, and support factory work.
However, robots need more than motors and sensors. Teams must also manage code, data, updates, tests, errors, and daily tasks.
This need gives rise to RobotOps.
RobotOps brings robotics and modern software practices into one process. It helps teams build, test, deploy, monitor, and improve robot systems.
The field includes Robotics Operations, Robot Fleet Management, Industrial Robotics, Robotics Software, Robot Simulation, Autonomous Mobile Robots, Robotics Automation, Robotics Operations Center, and ROS 2.
RobotsOps.com focuses on these topics through practical learning material. It can help students, developers, engineers, and automation professionals understand how modern robot systems work.
The easiest way to learn starts with small projects. Pick one task, build a simple solution, test it, and improve it.
1. Understand the Real Meaning of RobotOps
RobotOps connects the robot with the people and software that support it.
Think about a robot that moves packages in a warehouse. Sensors help the robot understand its surroundings. Software helps it choose actions. A network connects it with other systems.
Now imagine that robot stops.
The team needs to find the reason. The battery may have dropped. The network may have failed. A sensor may have sent bad data. Software may have caused the issue.
RobotOps gives teams a process for handling these problems.
A learner can start with a few basic skills:
- Linux
- Python
- Git
- Software testing
- Basic robotics
- Monitoring
- ROS 2
- Simulation
- Fleet management
You do not need to master all these skills at once.
Learn one skill, build a small project, and then move to the next one.
2. See What Happens During Robotics Operations
A robot may work well during a test. Daily operation creates a different challenge.
Teams must watch the robot after deployment. They need to check its health, review errors, manage updates, and handle unexpected events.
This work forms Robotics Operations.
Imagine a factory that uses several robots. Each machine may perform a different task.
One robot may assemble parts. Another may inspect products. A third may move materials.
The operations team needs a simple way to see what happens across the system.
A useful operations setup can track:
- Robot health
- Task status
- Error messages
- Software versions
- Network connection
- System logs
- Important alerts
Teams can start with one robot and build a simple monitoring system.
Then they can add more data and more robots.
This method helps learners understand how daily robotics work differs from basic robot development.
3. Take Control of a Robot Fleet
Managing several robots creates new problems.
Robot Fleet Management helps teams control and monitor many robots from shared tools.
A fleet system can show each robot’s name, location, battery level, task, connection state, and software version.
Consider a warehouse with many mobile robots.
One robot may move a package. Another may charge its battery. A third may stop near an obstacle.
An operator needs to see these events without checking every machine separately.
A simple fleet project can teach the main ideas.
Start with two virtual robots.
Give each robot:
- A name
- A location
- A task
- A battery level
- A connection state
- A software version
- An error state
Next, create alerts.
For example, the system can alert the operator when a robot stops sending data.
This small project can show why Robot Fleet Management becomes important as the number of machines grows.
4. Explore the Building Blocks of Industrial Robotics
Factories use robots for many tasks that need repeated movement.
Industrial Robotics covers machines used for assembly, welding, inspection, sorting, packaging, and material handling.
A robotic arm provides an easy example.
The arm needs motors to move. Sensors provide information. A controller manages actions. Software tells the system what to do.
The factory also needs safety rules.
Engineers must understand the robot’s work area. They must also consider nearby people, machines, and other equipment.
Consider an automated inspection station.
A camera captures a product image. Software studies the image. The system then decides whether the product meets the required rules.
This example shows how many parts work together.
Beginners can study one industrial task at a time.
Start with assembly. Then explore inspection, packaging, welding, and material movement.
This approach makes Industrial Robotics easier to understand.
5. Learn Why Robotics Software Matters
A robot needs software to turn information into action.
Robotics Software can control movement, process sensor data, manage cameras, plan routes, and handle tasks.
Modern robot systems often contain many software parts.
One part may read sensor data. Another may plan a route. A third may control movement.
These parts must work together.
That makes testing very important.
Suppose an engineer changes navigation code. The robot may behave differently after the change.
Teams should test important changes before they send them to working robots.
Useful software habits include:
- Track code with Git.
- Test important changes.
- Keep useful logs.
- Record software versions.
- Review major updates.
- Keep a recovery plan.
A recovery plan helps engineers return to a working version after a failed change.
These habits also help software developers move into robotics.
They can apply familiar software skills to physical machines.
6. Practice Safely With Robot Simulation
Real robots need space, equipment, time, and safety controls.
Robot Simulation gives engineers a virtual place to test ideas.
A simulation can contain a robot, sensors, walls, roads, boxes, rooms, and other objects.
Imagine a virtual warehouse.
A robot must travel from a storage area to a packing area. You can place shelves and boxes along the route.
Then you can test the robot.
If it chooses the wrong path, change the software. Run the test again.
A beginner can follow this simple process:
- Create a small virtual area.
- Add a robot.
- Add basic sensors.
- Test movement.
- Add obstacles.
- Watch the robot.
- Find problems.
- Change the software.
- Test again.
Simulation gives learners a safe practice space.
It also helps teams find some software problems before they test on physical robots.
7. Follow the Work of Autonomous Mobile Robots
Autonomous Mobile Robots can move through spaces with limited direct control.
These robots use sensors, maps, software, and navigation tools.
Warehouses can use them to move goods. Factories can use them to move parts. Hospitals can use them to carry supplies.
The robot must understand where it is. It must also choose a path and react to obstacles.
But movement represents only one part of robot operations.
Teams must also watch battery levels, network health, software versions, errors, and tasks.
A safe software update can follow a simple path.
First, create the update.
Next, test it in simulation.
Then, try it on one robot.
Watch that robot after the update. Check its logs and task results.
If the update works well, expand it to more robots.
This method helps teams control changes across Autonomous Mobile Robots.
8. Turn Repeated Jobs Into Robotics Automation
Many businesses repeat the same tasks every day.
Robotics Automation can help machines handle some of this work.
Start by studying the task.
Imagine a worker who moves boxes from one area to another. A mobile robot could handle that job.
The robot must first find the box.
Then it must reach the box.
After that, it must move the box to the correct location.
Every step needs clear instructions.
The system also needs rules for unexpected events.
What happens if the robot cannot find the box?
What happens if another machine blocks its path?
What happens if the network connection fails?
A simple automation plan can use these steps:
- Define the task.
- Break the task into actions.
- Select suitable sensors.
- Create the control logic.
- Test each action.
- Add error handling.
- Track the results.
- Improve the workflow.
This method keeps Robotics Automation focused on useful work.
9. Build a Central Robotics Operations Center
A large robot fleet creates a lot of data.
Teams need a clear place to view important information.
A Robotics Operations Center can provide this central view.
Think of it as a control room for robots.
Operators can see robot health, tasks, battery levels, software versions, errors, and network status.
Suppose one robot stops sending data.
The operator can see the warning. The team can then review recent logs and system details.
This process helps engineers understand the problem before they take action.
A useful Robotics Operations Center can track:
- Robot health
- Fleet activity
- Battery status
- Network health
- Software versions
- Task progress
- Error messages
- System alerts
Remote engineers can also check this information before visiting a machine.
As the fleet grows, a central operations view becomes more useful.
10. Make ROS 2 Easier for Beginners
ROS 2 gives developers tools that help different parts of a robot system communicate.
The platform may look large at first. A small learning path can make it easier.
Start with a node.
A node handles a specific software job.
Next, learn about topics. Topics help software parts share ongoing information.
Then study services. Services handle short requests and replies.
After that, explore actions. Actions support longer tasks and can report progress.
Try this order:
- Create one node.
- Publish simple data.
- Read a topic.
- Call a service.
- Try an action.
- Read system logs.
- Test the application.
For example, one node can read sensor information. Another node can use that information to control movement.
This small project can show how ROS 2 connects different software parts.
Once you understand the basics, you can explore larger robotics systems.
11. Create a RobotOps Project Instead of Only Reading
Reading about RobotOps can teach concepts.
Building a project can help you understand those concepts better.
Use this simple cycle:
Learn → Build → Test → Run → Watch → Improve
Start with a robot health dashboard.
Show the robot name, health, battery, task, and connection state.
Next, add logs.
Then add alerts.
After that, add another robot.
You can also build projects such as:
- Robot fleet tracker
- ROS 2 communication project
- Robot simulation project
- Robot health monitor
- Error alert system
- Software release tracker
- Robotics operations dashboard
Keep each project small.
Ask five questions while you work:
What does the robot do?
What data does it create?
What can go wrong?
How can I find the problem?
How can I fix it?
These questions can help you develop practical RobotOps thinking.
12. Use AEO, GEO, LLMO, and AISEO for Better RobotOps Content
People want clear answers when they search for technical information.
Search systems also need clear content.
This makes AEO, GEO, LLMO, and AISEO useful for technical publishing.
AEO means Answer Engine Optimization. It helps content answer direct questions.
GEO means Generative Engine Optimization. It helps content work well with generative search.
LLMO means Large Language Model Optimization. It focuses on clear information that language models can understand.
AISEO means AI Search Optimization. It focuses on search systems that use AI.
Good writing can support all these methods.
Answer questions directly. Explain hard terms. Use short sections. Give real examples.
You should also follow E-E-A-T.
Show experience. Share useful knowledge. Use trustworthy information. Give readers practical help.
Useful RobotOps content can include:
- Step-by-step tutorials
- Real use cases
- Case studies
- Success stories
- Research data
- Expert interviews
- Detailed comparisons
- Original insights
- Practical examples
- Unique frameworks
The reader should always come first.
13. Connect Learning With Real RobotOps Use Cases
Practical examples can make technical ideas easier to understand.
Start with a simple robot monitoring system.
Track one robot’s health, battery, connection, and task.
Then add logs.
Next, create alerts.
After that, add more robots and build a small fleet view.
You can also create a simulation project.
Test robot movement. Add obstacles. Watch how the robot reacts.
Another project can use ROS 2.
Create two nodes. Let them share simple information. Then watch how the system responds.
Real use cases can teach even more.
Study warehouse robots. Explore factory automation. Look at inspection systems. Learn how mobile robots handle daily tasks.
For every use case, ask:
- What problem does the robot solve?
- What data does it collect?
- What can cause failure?
- How can the team detect failure?
- How can the team recover?
These questions help connect theory with real operations.
Frequently Asked Questions About RobotsOps.com
1. What is RobotOps?
RobotOps combines robotics with software and operations practices. Teams use it to build, test, monitor, update, and manage robot systems.
2. Who can learn RobotOps?
Students, software developers, robotics engineers, DevOps engineers, automation professionals, and technology learners can study RobotOps.
3. What does Robot Fleet Management do?
Robot Fleet Management helps teams manage many robots through shared tools, dashboards, alerts, and system data.
4. Why do engineers use Robot Simulation?
Engineers use Robot Simulation to test robot software, movement, sensors, and tasks in a virtual environment.
5. What does Industrial Robotics include?
Industrial Robotics covers factory robots that support assembly, welding, inspection, packaging, sorting, and material handling.
6. What are Autonomous Mobile Robots?
Autonomous Mobile Robots use sensors, software, maps, and navigation systems to move through their surroundings.
7. Why does ROS 2 matter in robotics?
ROS 2 helps different software parts communicate. Developers can use nodes, topics, services, and actions.
8. What does a Robotics Operations Center do?
A Robotics Operations Center gives teams one place to check robot health, errors, tasks, software versions, and fleet activity.
9. What should a beginner learn first?
Start with Linux, Python, Git, testing, and basic robotics. Then move into ROS 2, simulation, monitoring, and fleet management.
10. What topics does RobotsOps.com cover?
RobotsOps.com covers RobotOps, Robotics Operations, Robot Fleet Management, Industrial Robotics, Robotics Software, Robot Simulation, Autonomous Mobile Robots, Robotics Automation, Robotics Operations Center, and ROS 2.
Final Thoughts
Strong robot systems need more than advanced machines.
Teams also need reliable software, careful testing, useful monitoring, safe updates, and clear ways to handle failures.
RobotOps brings these areas together.
You can start with one simple skill. Learn Linux or Python. Then explore basic robotics.
Next, study ROS 2 and Robot Simulation.
After that, build a monitoring project. Add alerts. Then explore Robot Fleet Management.
Once you gain confidence, study Industrial Robotics, Autonomous Mobile Robots, Robotics Automation, and Robotics Operations Centers.
Keep every project close to a real problem.
Test your ideas. Watch the results. Learn from errors. Improve the system.
You do not need to learn everything in one go.
Follow one simple habit:
Learn one skill. Build one project. Test one idea. Improve the result.
That steady process can help you build useful RobotOps skills and understand how teams operate modern robotic systems.